Multi-Fidelity Policy Gradient Algorithms
Xinjie Liu, Cyrus Neary, Kushagra Gupta, Christian Ellis, Ufuk Topcu, David Fridovich-Keil
arXiv preprint arXiv:2503.05696, 2025
Academic Researcher & Robotics Engineer
I create robust, adaptable, and safe autonomous systems leveraging machine learning, control, and computer vision to excel in challenging real-world scenarios.

About
Christian Ellis is a joint postdoctoral researcher with the DEVCOM Army Research Laboratory and the Center for Autonomy at The University of Texas at Austin, focused on building safe and robust algorithms for autonomous systems which can operate in environments beyond where they were trained. His research interests include safe inverse reinforcement learning, environmental uncertainty quantification, open world learning, test and evaluation, and formal verification.
Resulting publications provide applied solutions to real world autonomous systems. Christian received both a Ph.D. in Electrical and Computer Engineering in 2024 for his dissertation titled, “Terrain Aware Autonomous Ground Navigation in Unstructured Environments Informed by Human Demonstrations,” and a B.S. in Computer Science: Software Engineering in 2019 from the University of Massachusetts, Dartmouth.
Expertise
Applying deep learning, reinforcement learning, and other ML techniques to improve robot capabilities in navigation, manipulation, and decision-making tasks.
Developing advanced perception systems that enable robots to understand and interpret their environment through visual data, depth sensing, and multi-modal fusion.
Leading teams to develop and test software for autonomous systems, including perception, navigation, and control.
Developing and testing software for autonomous systems, including perception, navigation, and control.
Conducting research in real world robotics and autonomous systems to develop novel algorithms and methodologies.
Providing expert guidance on robotics and autonomous systems, including development, acquisition, testing, and deployment.
Research
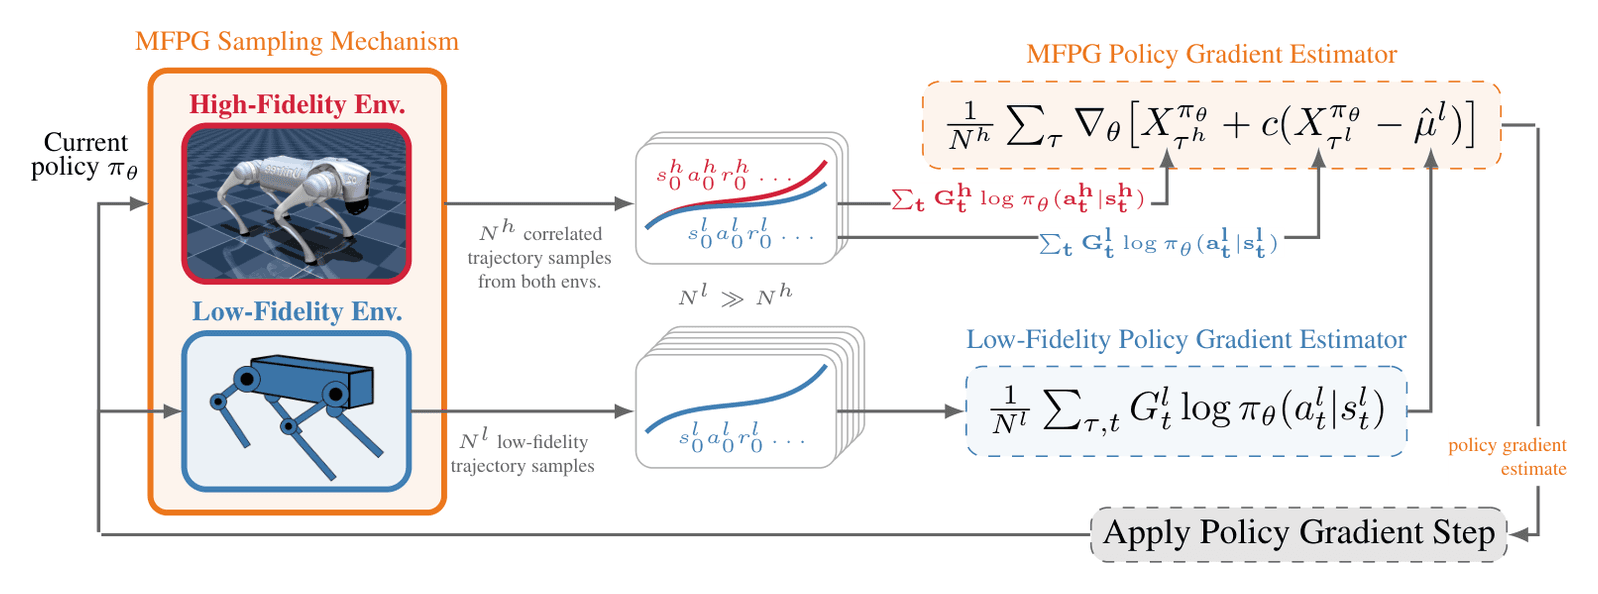
Xinjie Liu, Cyrus Neary, Kushagra Gupta, Christian Ellis, Ufuk Topcu, David Fridovich-Keil
arXiv preprint arXiv:2503.05696, 2025
Peng Jiang, Kasi Viswanath, Akhil Nagariya, George Chustz, Maggie Wigness, Philip Osteen, Timothy Overbye, Christian Ellis, Long Quang, Jia Huang, Srikanth Saripalli
arXiv preprint arXiv:2501.19274, 2025
Christian C. Ellis
University of Massachusetts Dartmouth, 2024
Christian Ellis, Maggie Wigness, Lance Fiondella
2022 IEEE International Conference on Assured Autonomy (ICAA), 2022
Media coverage
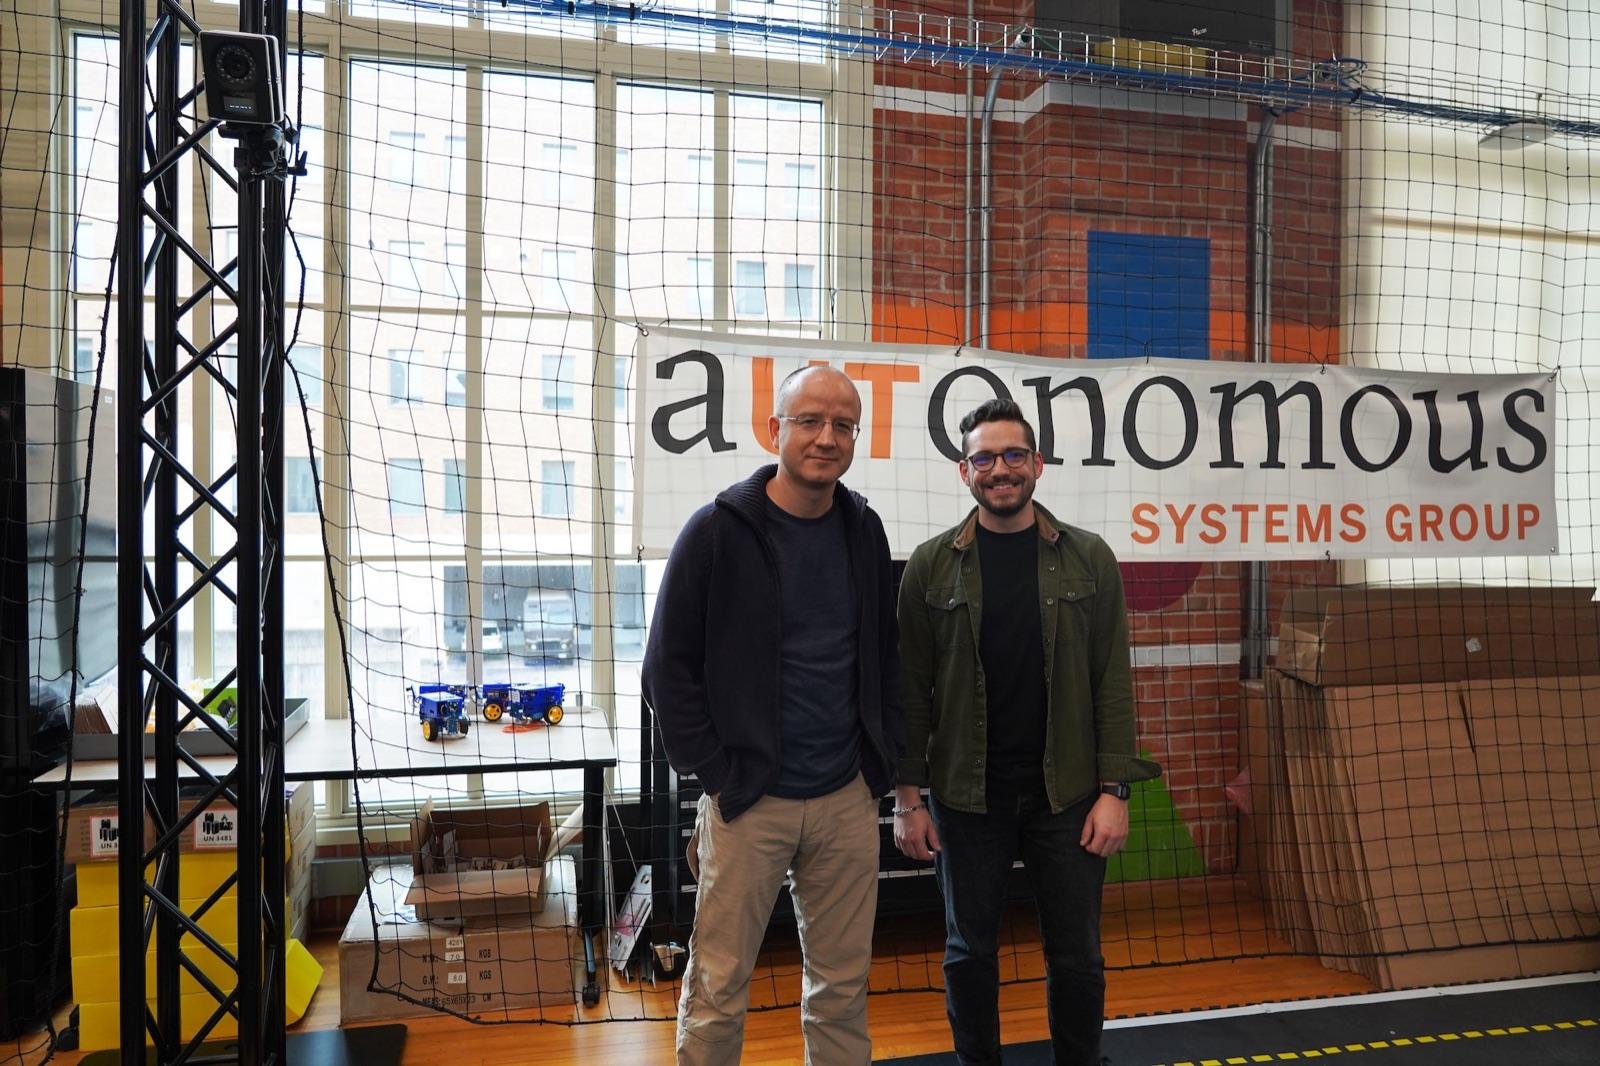
UT News
Featured researcher
“…joint UT-Army researcher Christian Ellis contributes his engineering expertise to build safe and robust learning-enabled, off-road ground systems…”
Oden Institute, UT Austin
Research mentor
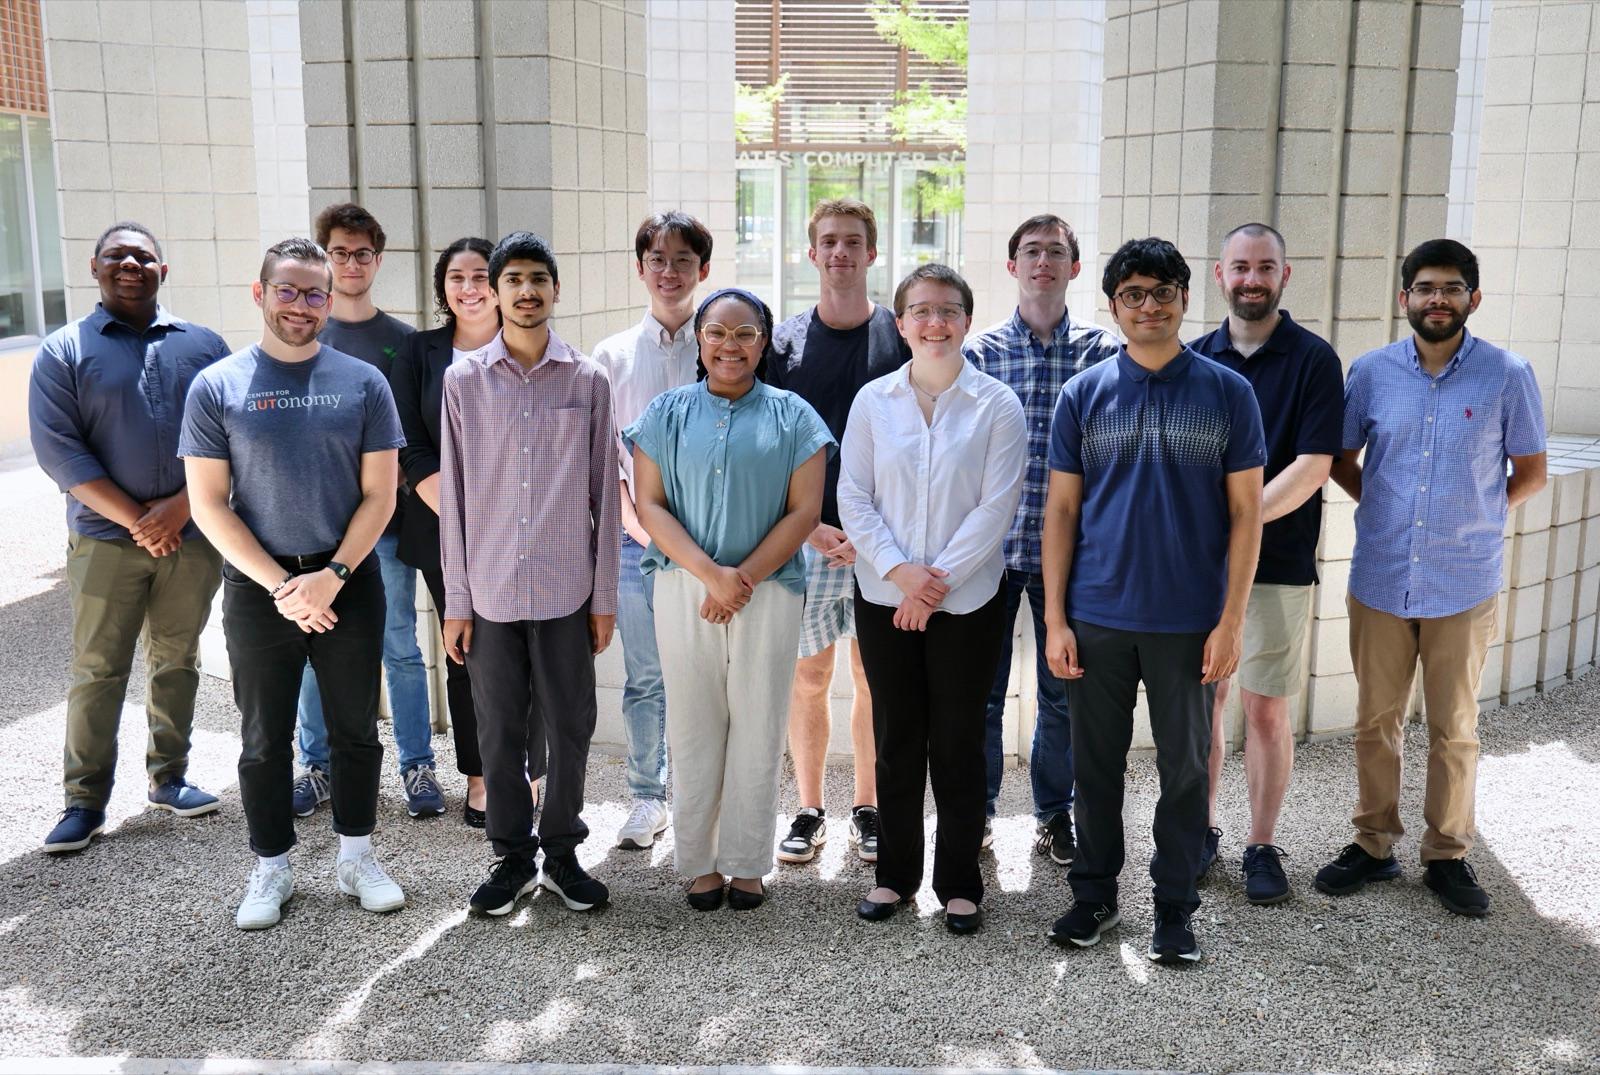
“Under the guidance of research mentor Dr. Christian Ellis and Ph.D. students, participants break down complex research objectives into achievable tasks…”
Austin American-Statesman
Pictured
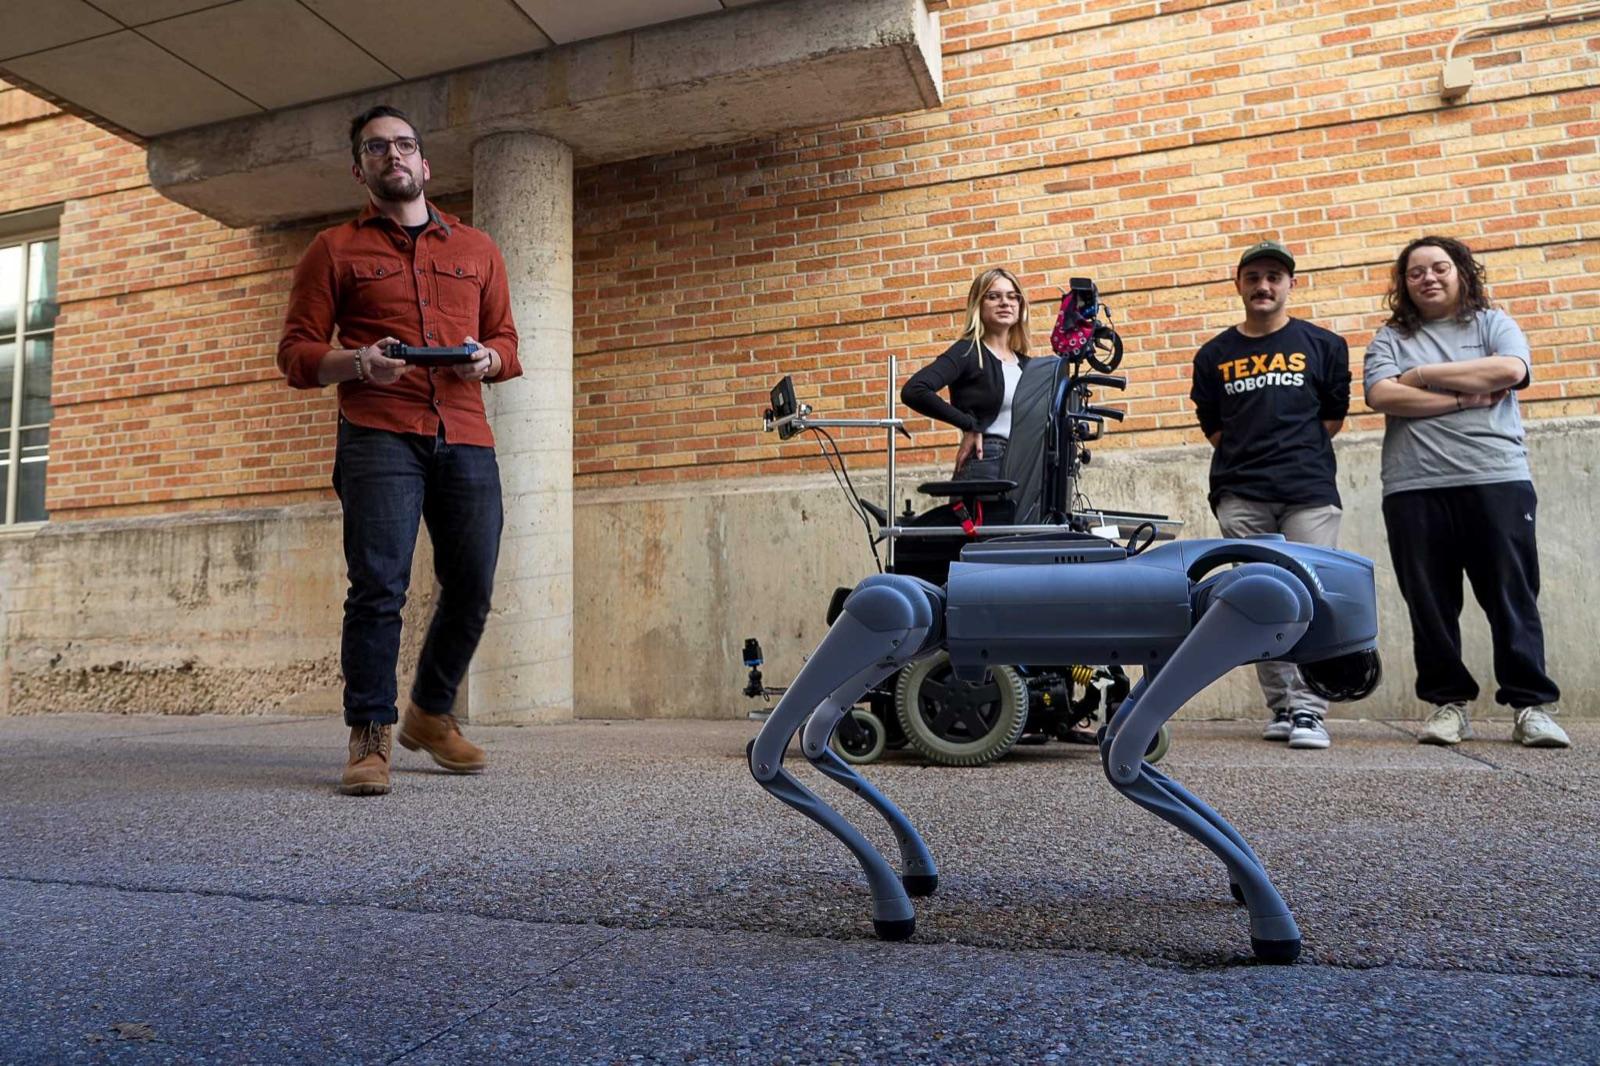
“Christian Ellis, a post-doctoral researcher, controls a quadrupedal robot ahead of the Texas Robotics parade…”
Also covered by Center for Autonomy, UT Austin
UMass Dartmouth News
Quoted
“Dr. Fiondella’s mentorship opened my eyes that I could achieve anything.”
Photo credits: UT News; Oden Institute, UT Austin; Aaron E. Martinez / American-Statesman; UMass Dartmouth.